01Research Assistant · 2026
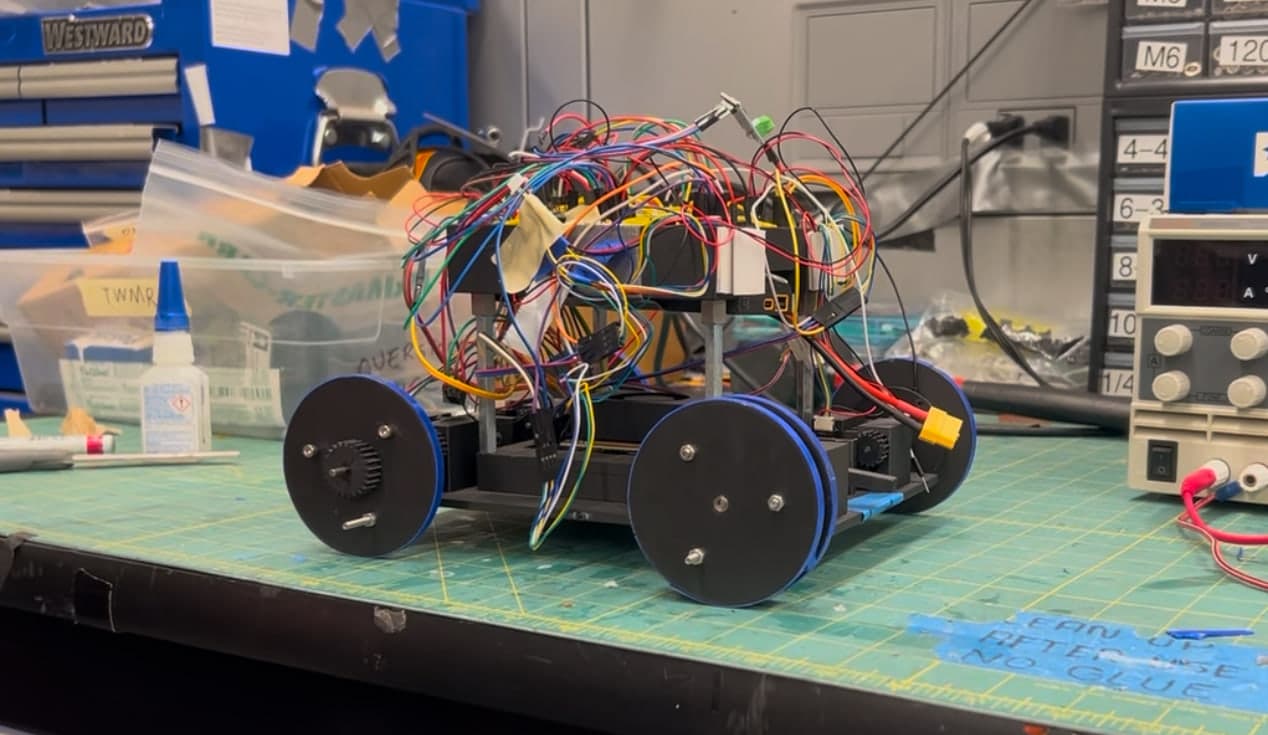
Transformable Wheel Mobile Robot
A 4-wheeled robot with radially extending legs that navigates varied terrain via Rapid Motor Adaptation.
Mechanical Engineering · UCSB ’28
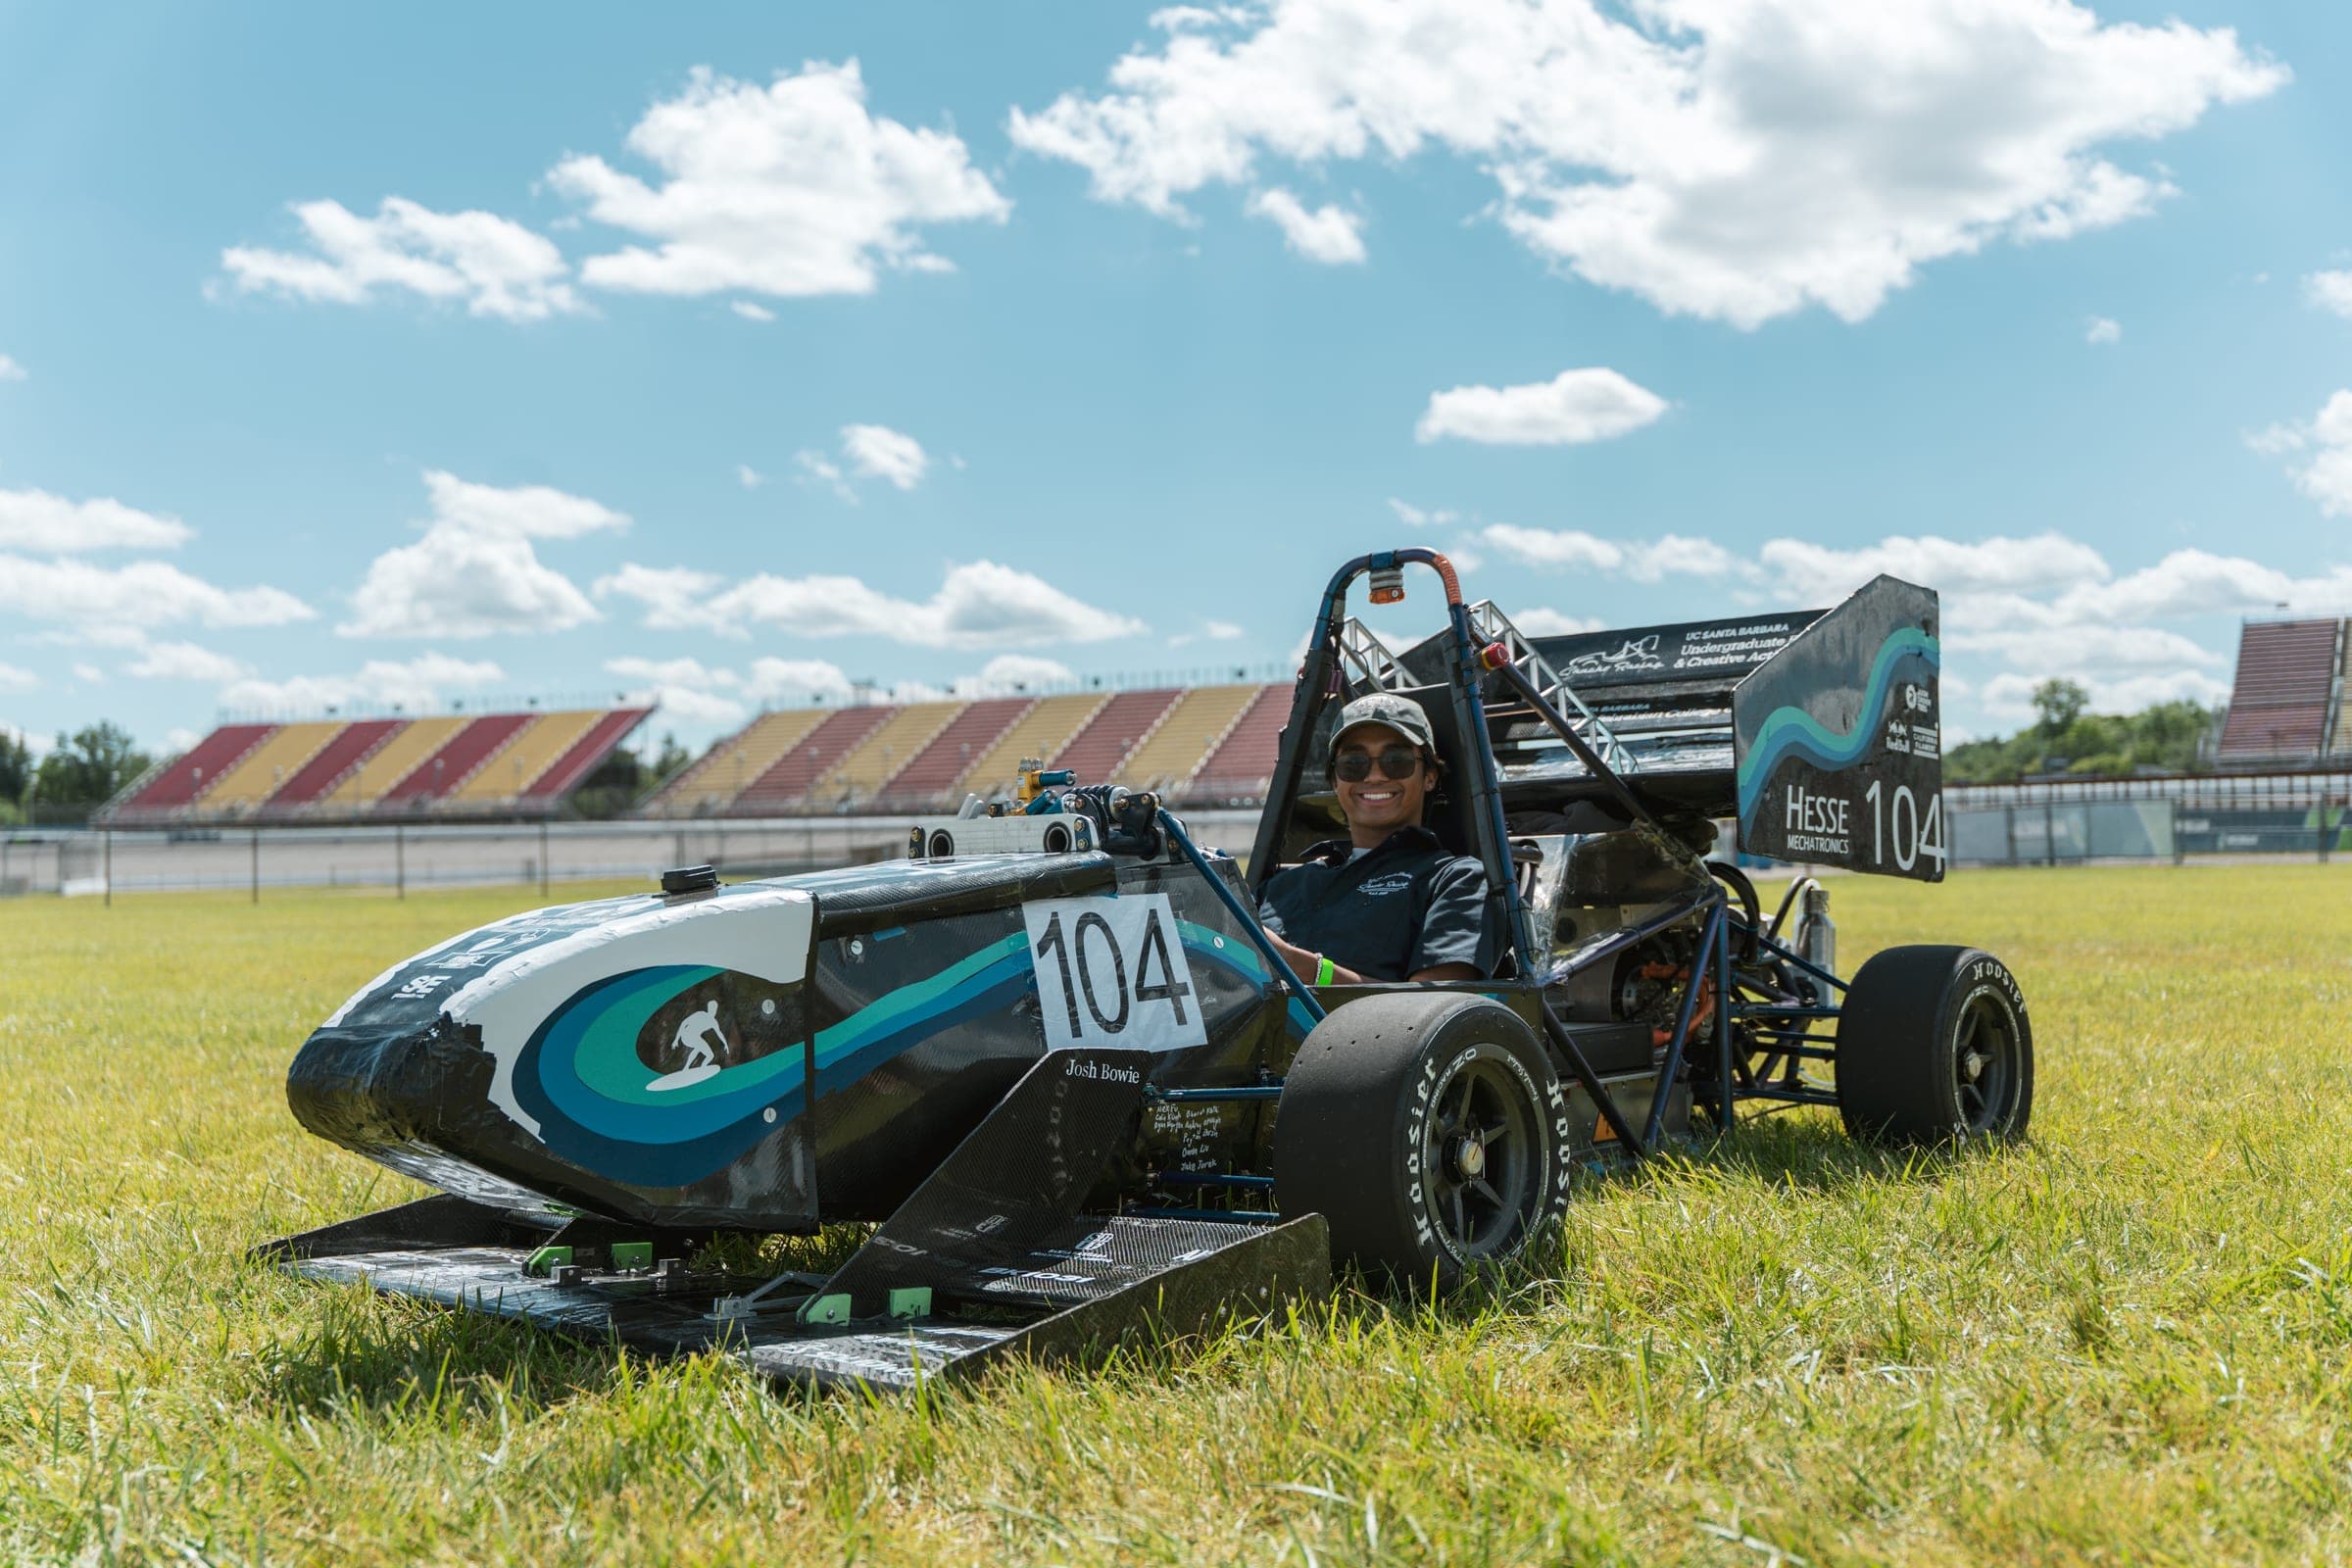
I'm a mechanical engineering student at UC Santa Barbara. I work on a transformable wheel robot as a research assistant, and on the chassis for Gaucho Racing, UCSB's Formula SAE team.
A 4-wheeled robot with radially extending legs that navigates varied terrain via Rapid Motor Adaptation.
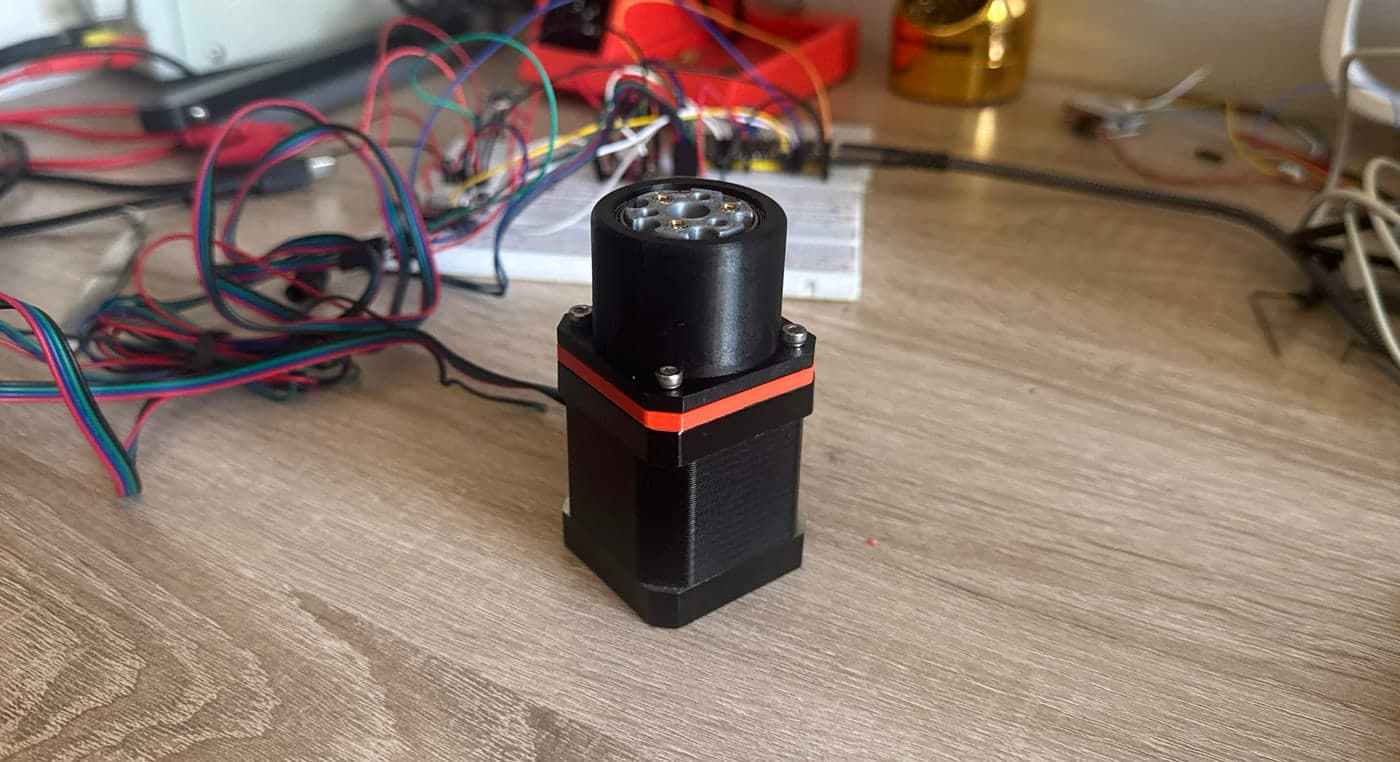
A cycloidal gearbox redesigned over 4+ iterations to fit within the dimensions of a NEMA 17 motor faceplate, at 42.3mm × 42.3mm × 34mm.
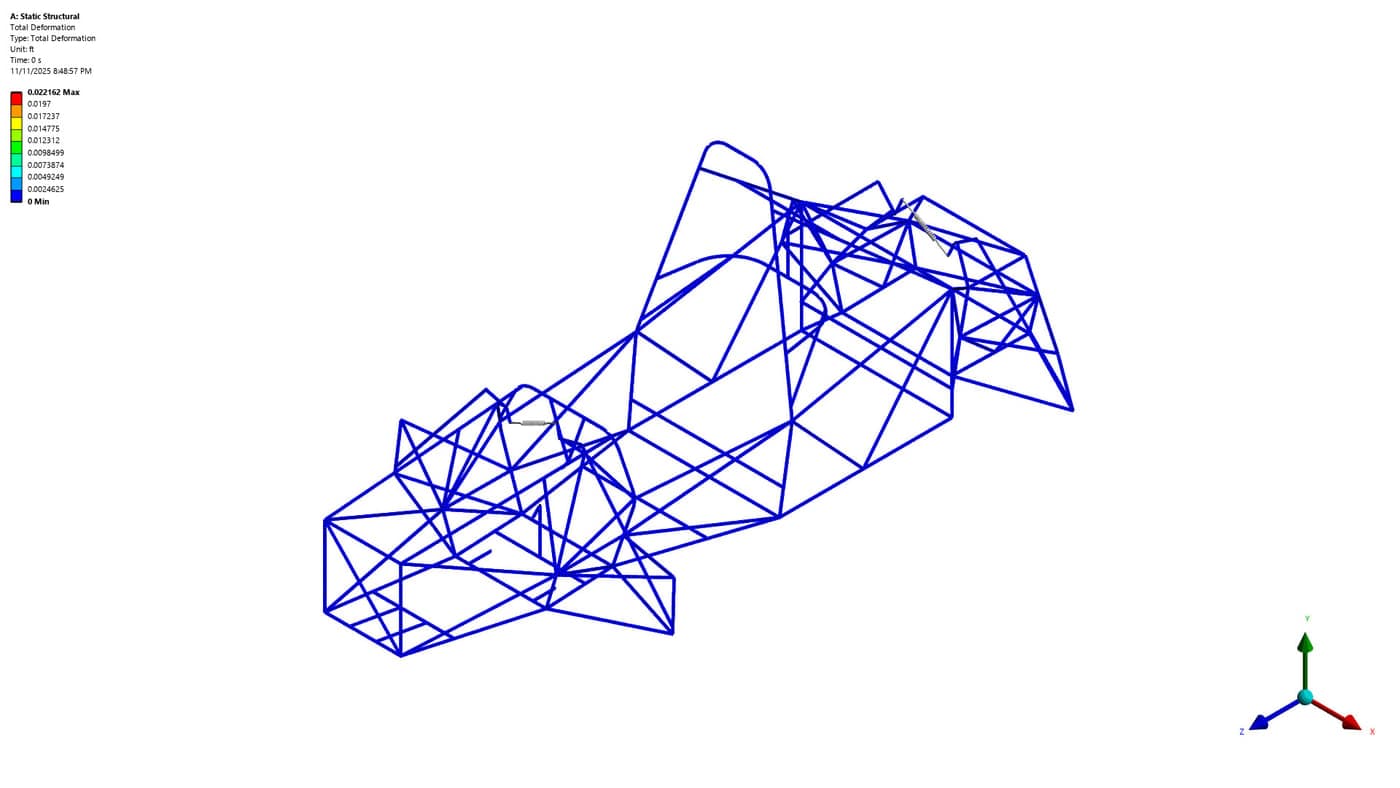
Structural revisions to an FSAE chassis frame through FEA and an experimental test fixture for validation.
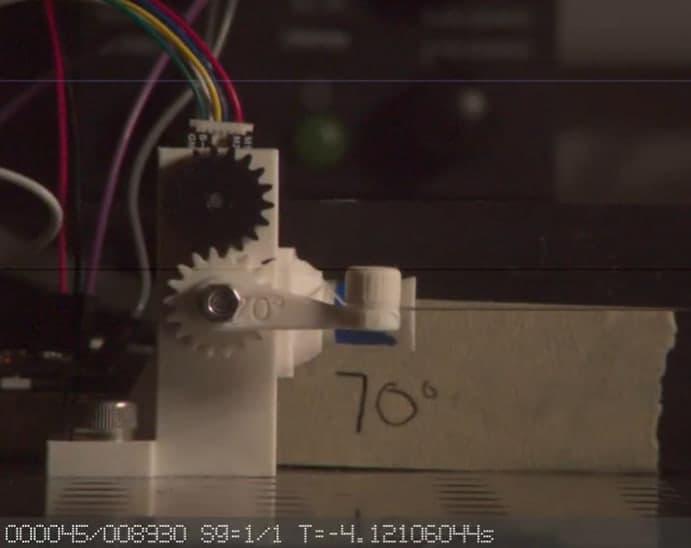
A latch-release mechanism inspired by the slingshot spider's web-catapult.
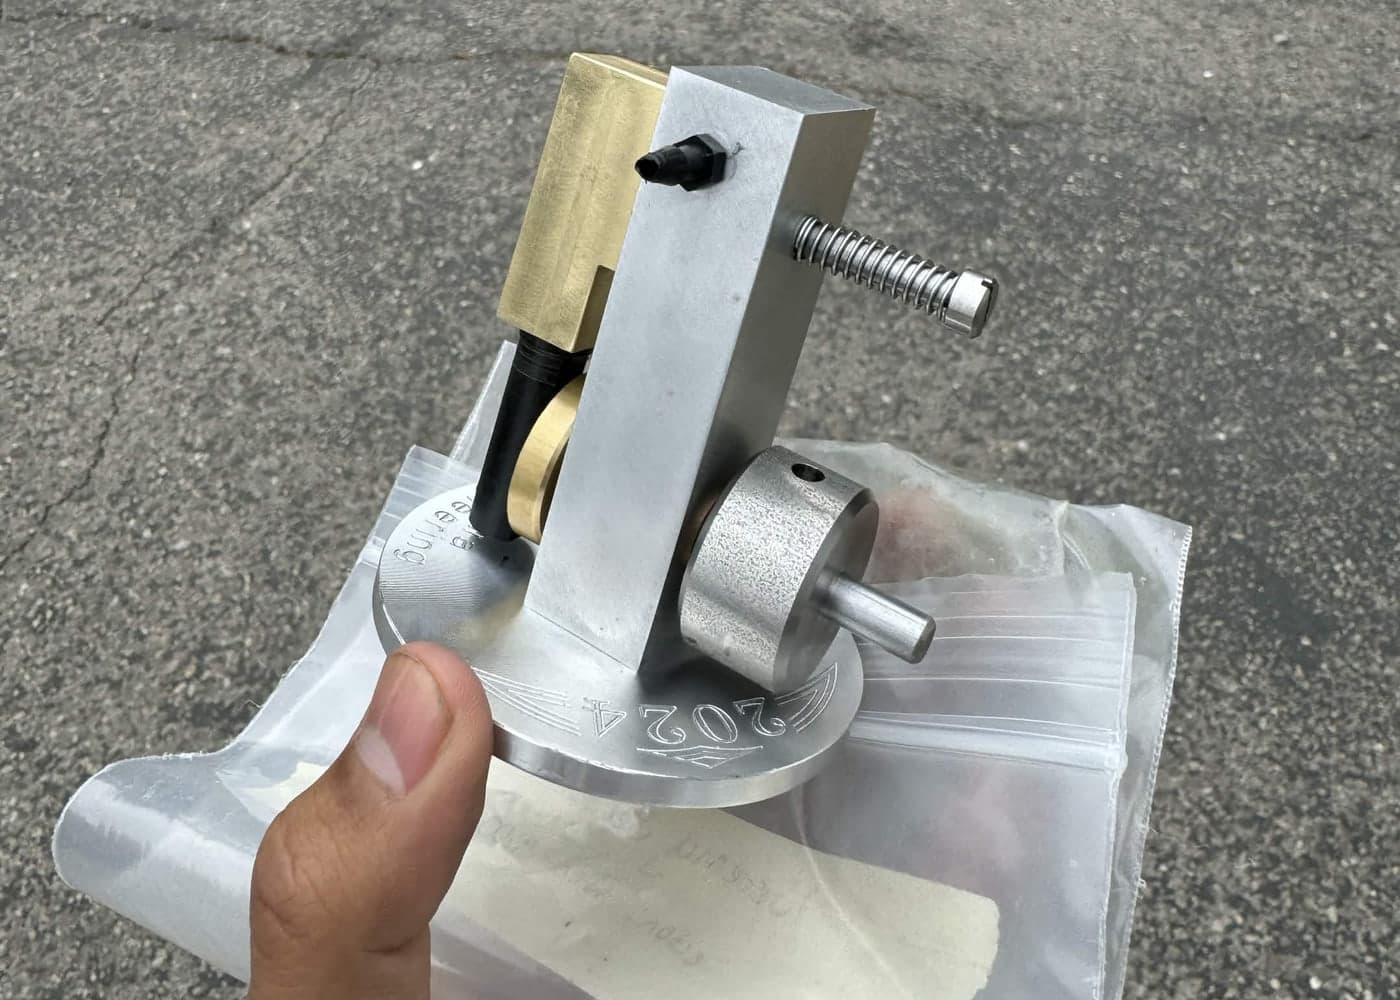
Machined a running air motor from stock, with fits held tight enough to seal without additional gasketing.